Deep-Sea Soft Robotic Drive
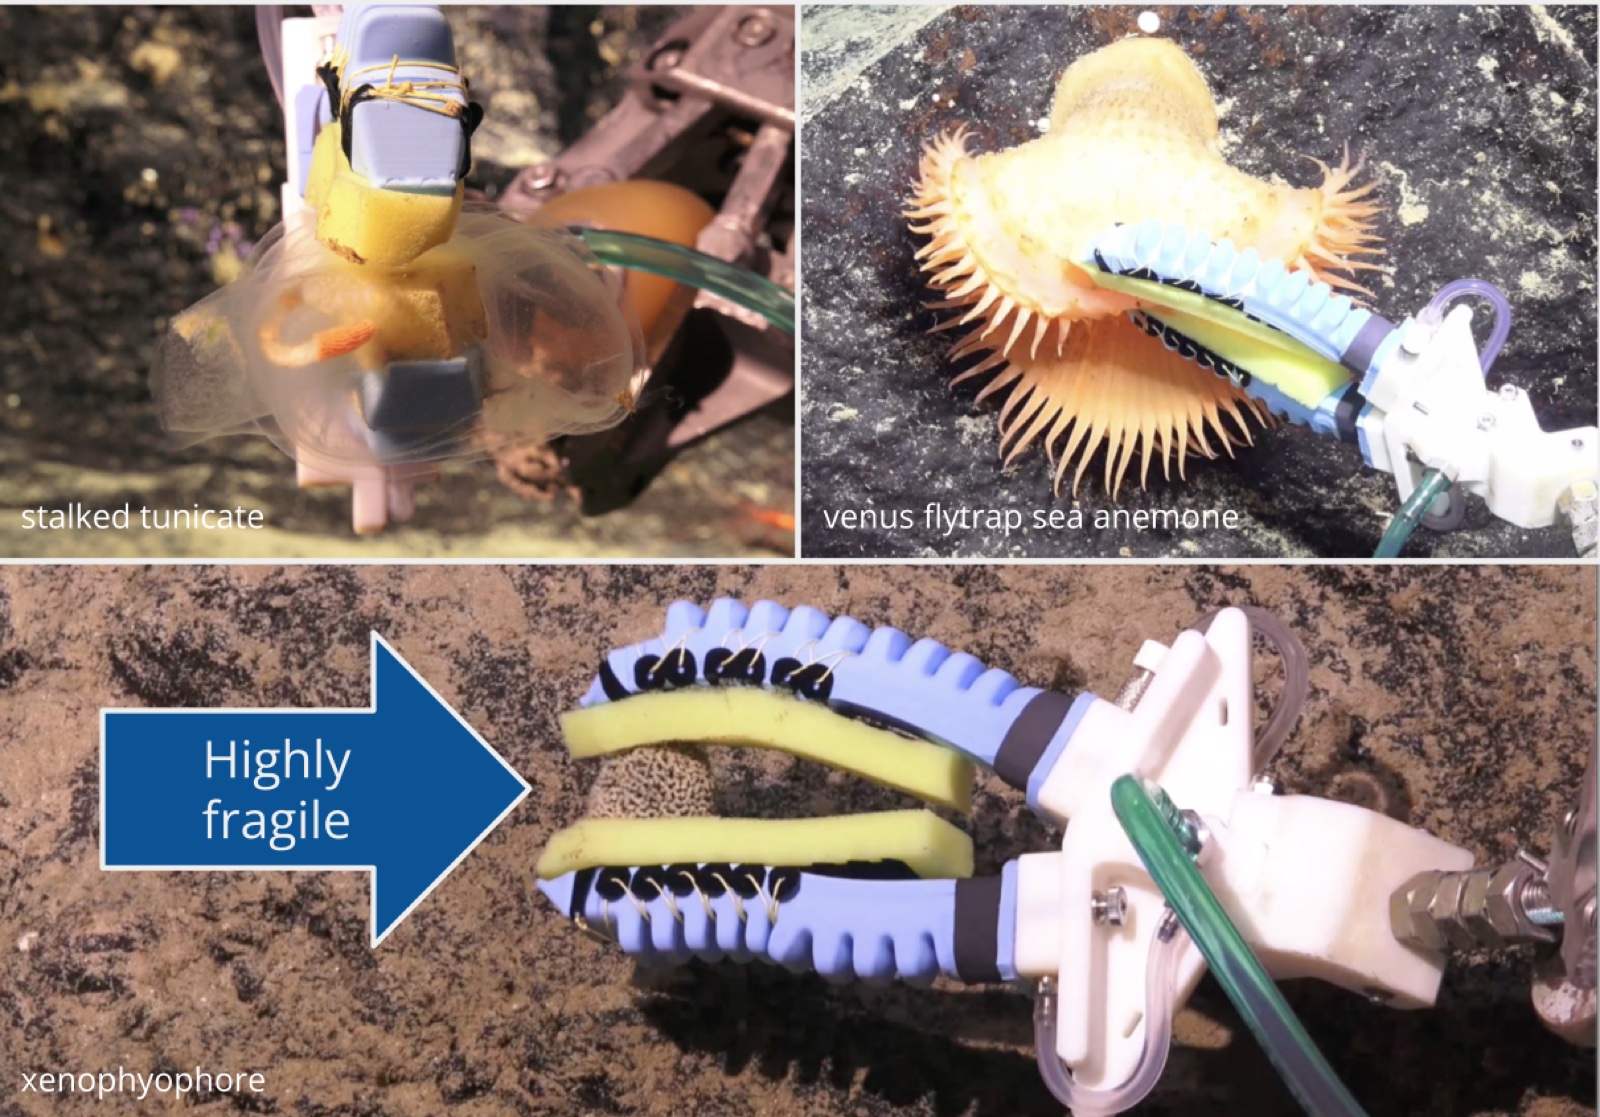
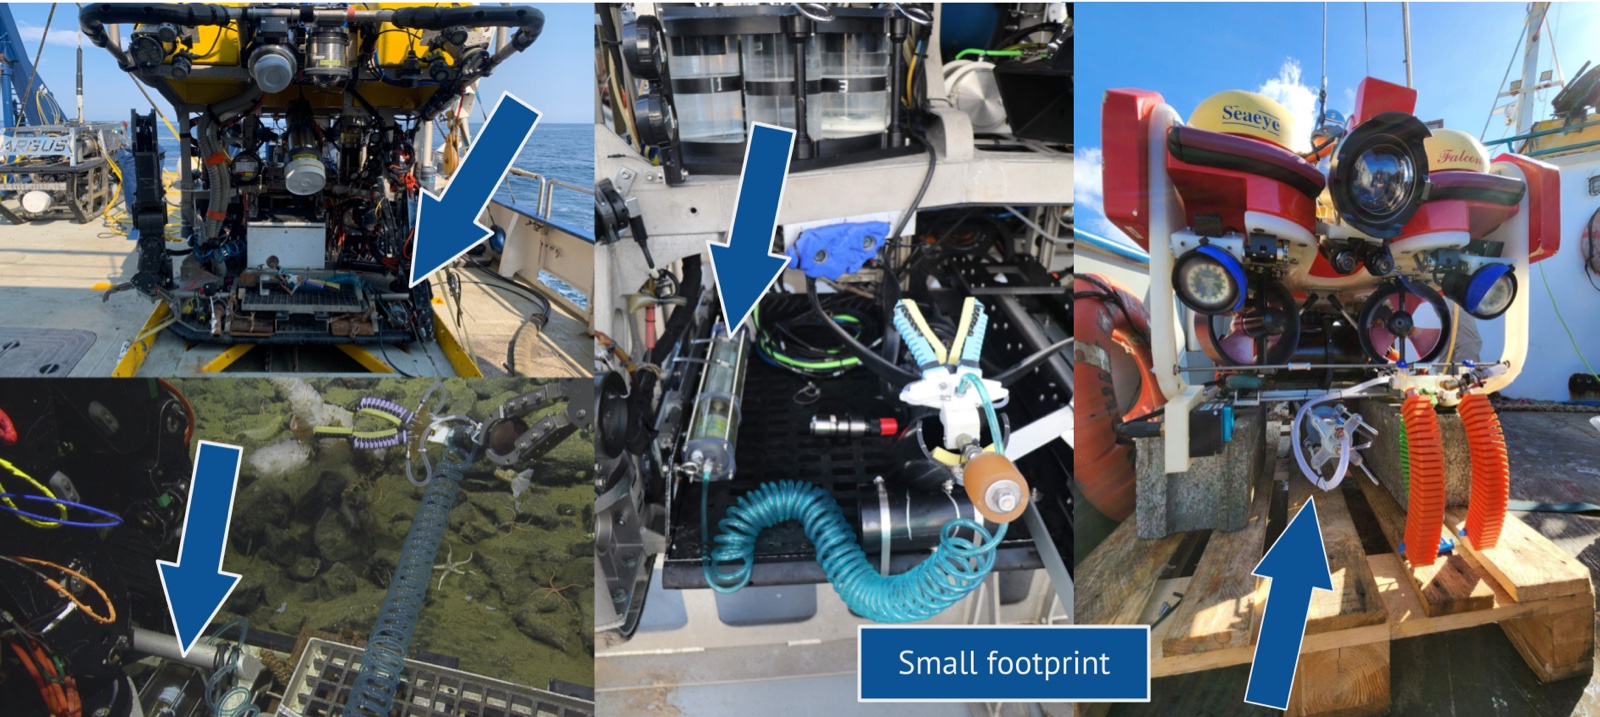
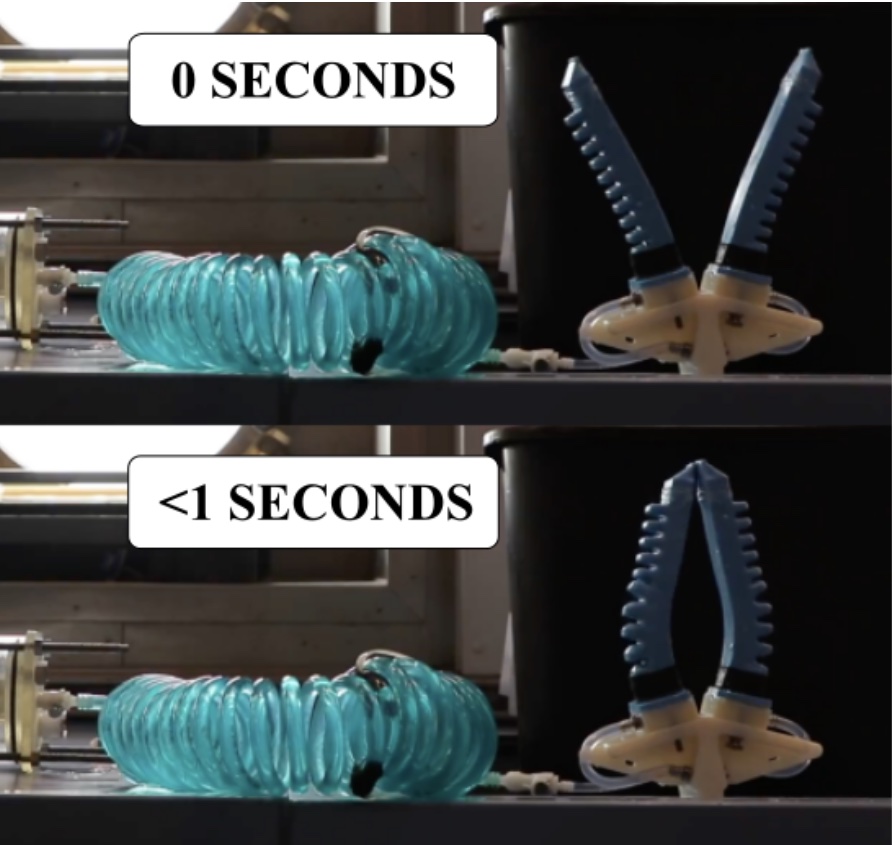
Soft robotic grippers can handle fragile deep-sea animals, but the pneumatic drives that power them on land fail at deep-sea pressures. This project built a pressure-compensated hydraulic drive that moves fluid directly from a servo-driven bellows to the actuator, with a 72 W peak draw. Prototypes ran on multiple ROVs to almost 4000 m and grasped and released a stalked tunicate, a Venus flytrap anemone, and a xenophyophore without harm. Work with Brennan Phillips and Stephen Licht at URI, with the Harvard Microrobotics Lab.
Research Products
- Paper: Rapid design and production of soft actuators using dynamic modeling and additive manufacturing for underwater applications American Control Conference, 2023, Yin, Shomberg et al.
- Paper: A predictable design and production workflow for field deployable underwater soft actuator applications OCEANS 2024 Singapore, Yin et al.
- Dissertation: Advances in deep-sea imaging and soft robotics, Chapter 1 URI, 2023
- Talk: Powering deep sea soft robotics Oceanology International Americas, San Diego, 2023
- Talk: Hydraulic drive for deep-sea soft robotic actuators New England Manipulation Symposium, Northeastern, 2024
Media and Outreach
- Powering the Hold Schmidt Ocean Institute cruise log, R/V Falkor, 2019
- URI is designing the future of deep-sea exploration URI News, 2019